pilot
PsiBot (Shanghai PsiBot Technology Co., Ltd. / 上海灵初智能科技有限公司)
Psi V1 (ψ-MobiDex)
- 180 cmheight
- 5 kgpayload
- —price
Data from manufacturer datasheets and product pages; median over the models of this category in the database.
Unveiled in April 2026 and still at prototype stage, the ψ-SynRobot is the wheeled humanoid that Shanghai-based PsiBot builds around its own PSI foundation models (Psi R1 and R2, a vision-language-action family).
Price from
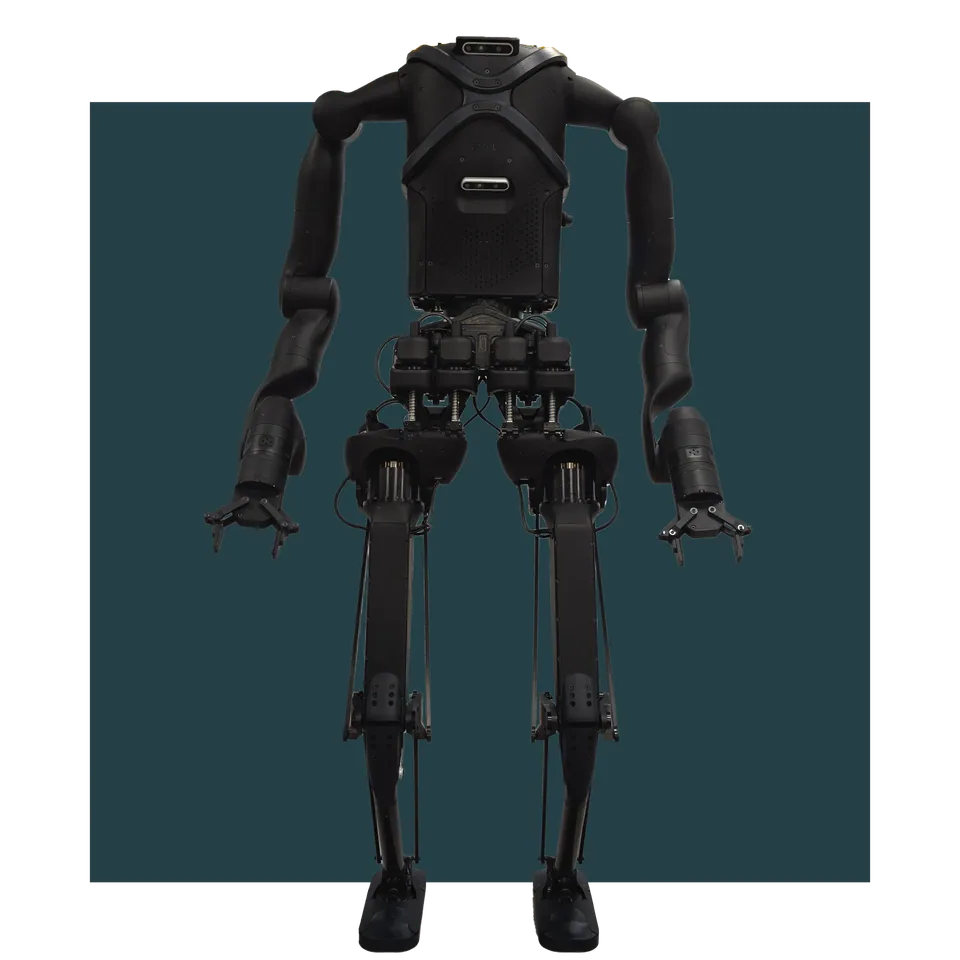
Unveiled in April 2026 and still at prototype stage, the ψ-SynRobot is the wheeled humanoid that Shanghai-based PsiBot builds around its own PSI foundation models (Psi R1 and R2, a vision-language-action family). The robot rides on four omnidirectional wheels at 0.1 to 1.5 m/s, climbs slopes of up to 5 degrees and stands, according to the maker, below 180 cm; no weight is published.
Each arm lifts 5 kg at a reach of 683 mm and ends in the in-house ψ-SynHand, a five-finger hand offered with 11 or 21 degrees of freedom. The maker itemises two neck joints, two hip joints, one knee and one ankle joint, but does not state the number of arm axes. Drive is electric with joint force control, joint brakes and an EtherCAT bus.
Perception combines a stereo RGB camera, three fisheye cameras, an RGBD camera in the head, a wrist RGBD camera, an IMU in the hip and two multi-line LiDARs in the base, all processed on an NVIDIA Jetson Thor; teleoperation is supported. PsiBot claims more than 8 hours of movement per charge, cable or automatic charging, 30 days of continuous operation and an emergency stop.
Intended jobs are order picking, scanning, labelling, 3C assembly and tool use such as barcode scanners or vacuum grippers in logistics, light industry and retail. It succeeds the Psi V1 platform, which ran on the older Jetson AGX Orin. No customers are named and the price is available on request.
no data
No confirmed distributor in Poland
PsiBot (Shanghai PsiBot Technology Co., Ltd. / 上海灵初智能科技有限公司)
Model unveiled
Shop links may become affiliate links in future, details: How we make money · How we check