on sale
no official photo
Data from manufacturer datasheets and product pages; median over the models of this category in the database.
Robot handsprototype
Psi H1
Psi H1 is an entry that needs a caveat: on the website of Shanghai-based PsiBot this name belongs to a teleoperation glove, under 240 g with latency below 3 ms and able to drive hands from 2 to 21 degrees of freedom, not to a hand.
- 1.1kgWeight
- 21DOFDegrees of freedom
- 5kgPayload
Key facts
- Specificationsweight 1.1 kg · degrees of freedom 21 DOF · payload 5 kg
- Statusprototype
- Availability in Polandnot confirmed
Summary
- ManufacturerPsiBot (Shanghai PsiBot Technology Co., Ltd. / 上海灵初智能科技有限公司)
- CategoryRobot hands
- Statusprototype
- Availability in PolandNo confirmed distributor in Poland
Psi H1 is an entry that needs a caveat: on the website of Shanghai-based PsiBot this name belongs to a teleoperation glove, under 240 g with latency below 3 ms and able to drive hands from 2 to 21 degrees of freedom, not to a hand.
The figures given here come from the maker's brochure for the WRC 2026 show and describe a hand called ψ-SynHand; the maker does not confirm that the two are the same product, so the catalog lists the model as a prototype.
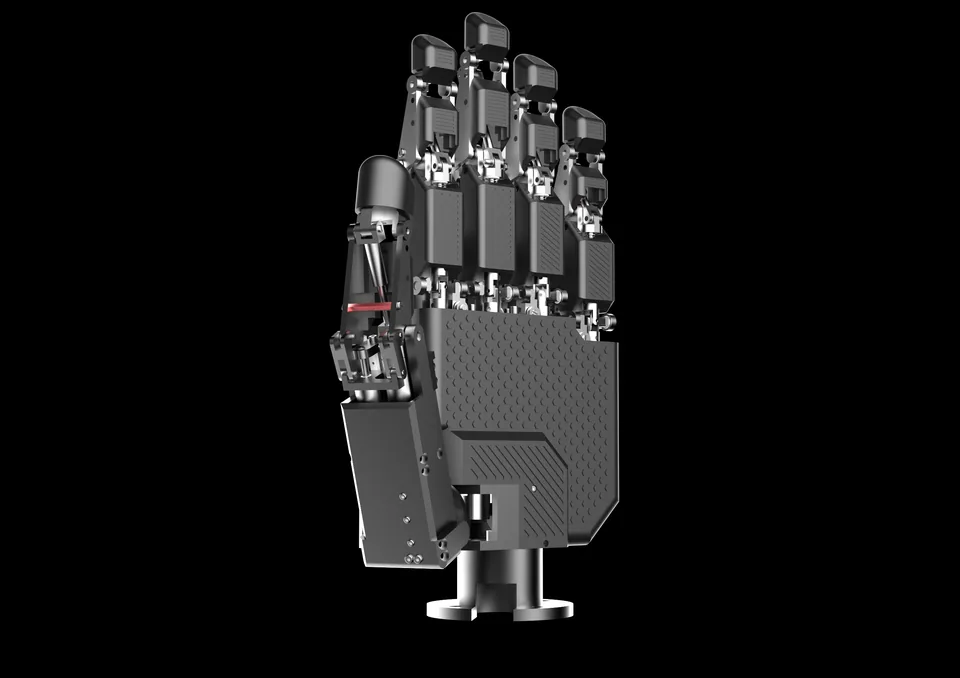
According to the brochure the hand has 21 degrees of freedom, 16 of them driven by motors through coupling gears and linkages, weighs 1.1 kg, carries 5 kg dynamically and 20 kg statically, and repeats to ±0.3 mm. It runs on 24 V, drawing about 0.35 A idle and about 5 A at most.
Three-axis force sensors sit in the fingertips and a pressure sensor in the palm; control covers position, velocity and torque, with force feedback from the current loop and the tactile sensors. Integration is via Linux with ROS and ROS 2, a C++ and Python SDK, and URDF and USD models for MuJoCo, Isaac Lab and Isaac Gym. The brochure does not state the finger count.
The hand targets humanoids and teleoperation; the price is on request. Another Chinese hand with 21 joints is the tendon-driven Linker Hand L30 Pro.
Specs
-
Weight1.1 kg+57% vs. the category median (0.7 kg, n=98)
-
Degrees of freedom21+31% vs. the category median (16, n=125)
-
Payload5 kg−67% vs. the category median (15 kg, n=83)
- category medianA higher value doesn't always mean a better robot; it depends on the application.
Dimensions and weight
- Weight
- 1.1 kg
Motion and manipulation
- Degrees of freedom
- 21
- Payload
- 5 kg
Electronics and AI
- Drive
- motors in the hand, coupling gears and linkages
- Sensors
- three-axis fingertip force sensors, palm pressure sensor
Additional specs
- Design type
- multi-finger hand
- Interfaces
- Linux, ROS/ROS 2, C++/Python SDK; URDF, USD
- Actuators
- 16
- Tactile sensing
- yes
- Supply voltage (V)
- 24
- Open source
- no
- Country of origin
- CN
Price and availability in Poland
no data
Dealers in Poland
No confirmed distributor in Poland
Applications
Typical applications
Target group
Comparison
Robot comparison toolSimilar models
 prototype
- on sale
 pilot
- on sale
- on sale
History
no data
Sources
Shop links may become affiliate links in future, details: How we make money · How we check