prototype
no official photo
Data from manufacturer datasheets and product pages; median over the models of this category in the database.
Humanoid robotsprototype
Origin
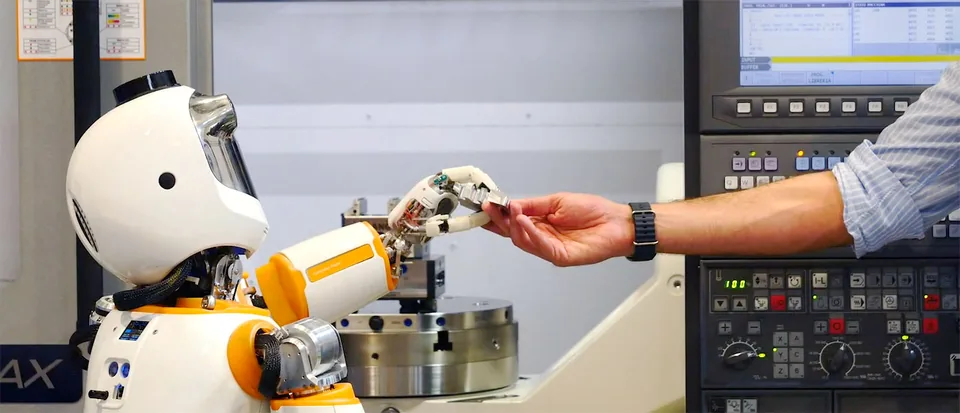
Origin stays put. The dual-arm robot from HIRO Industries in Corvallis, Oregon, founded by Lex Roller and Ethan Marreel, is bolted to a stationary foundation and works at a human-scale workstation.
Price from
no public price
No confirmed distributor in Poland
- 17DOFDegrees of freedom
Key facts
- Specificationsdegrees of freedom 17 DOF
- Statusprototype
- Availability in Polandnot confirmed
Summary
- ManufacturerHIRO Industries
- CategoryHumanoid robots
- Statusprototype
- Availability in PolandNo confirmed distributor in Poland
Origin stays put. The dual-arm robot from HIRO Industries in Corvallis, Oregon, founded by Lex Roller and Ethan Marreel, is bolted to a stationary foundation and works at a human-scale workstation. Two seven-joint arms and a lift axis that raises or lowers the torso give 17 degrees of freedom in total, counted as 14 in the arms, 2 in the grippers and 1 in the lift.
The grippers are compliant two-finger parallel units rather than multi-finger hands. Vision comes from three RGB-D cameras, one in the head and one on each wrist, delivering 1280 by 800 colour images at up to 60 frames per second and depth at up to 30. The intended tasks are packing, kitting and assembly, and HIRO is working with manufacturers near its base, though no launch date has been set.
Height, weight and payload have not been published, so figures found elsewhere are unconfirmed. Status is prototype and the price is on request. Since Origin is a fixed dual-arm manipulator rather than a humanoid in the strict sense, the closest comparison in the catalogue is the mobile JAKA Kargo, which performs similar handling tasks from a wheeled base, or the stationary-style work of Neura MAiRA S.
Specs
-
Degrees of freedom17−42% vs. the category median (29.5, n=200)
- category medianA higher value doesn't always mean a better robot; it depends on the application.
Motion and manipulation
- Degrees of freedom
- 17
- Hand degrees of freedom
- 1
Electronics and AI
- Drive
- electric, two seven-joint arms, lift axis, fixed foundation
- Sensors
- three RGB-D cameras in head and wrists, 1280×800 up to 60 fps
Additional specs
- Form factor
- stationary dual-arm robot
- Fingers
- 2
- Country of origin
- US
- Hand type
- Parallelgreifer (nachgiebig)
Price and availability in Poland
no data
Dealers in Poland
No confirmed distributor in Poland
Applications
Typical applications
Target group
Comparison
Robot comparison toolSimilar models
- prototype
- prototype
- pilot
- research platform
 prototype
History
no data
Sources
Shop links may become affiliate links in future, details: How we make money · How we check