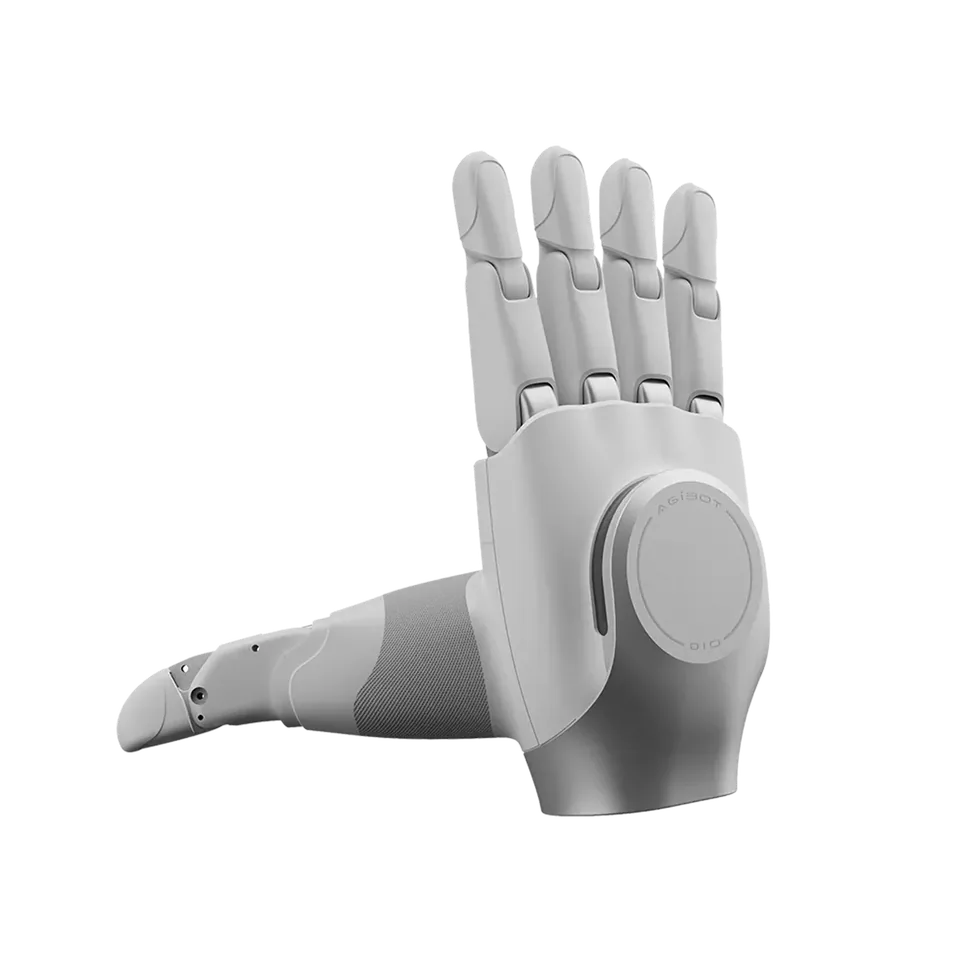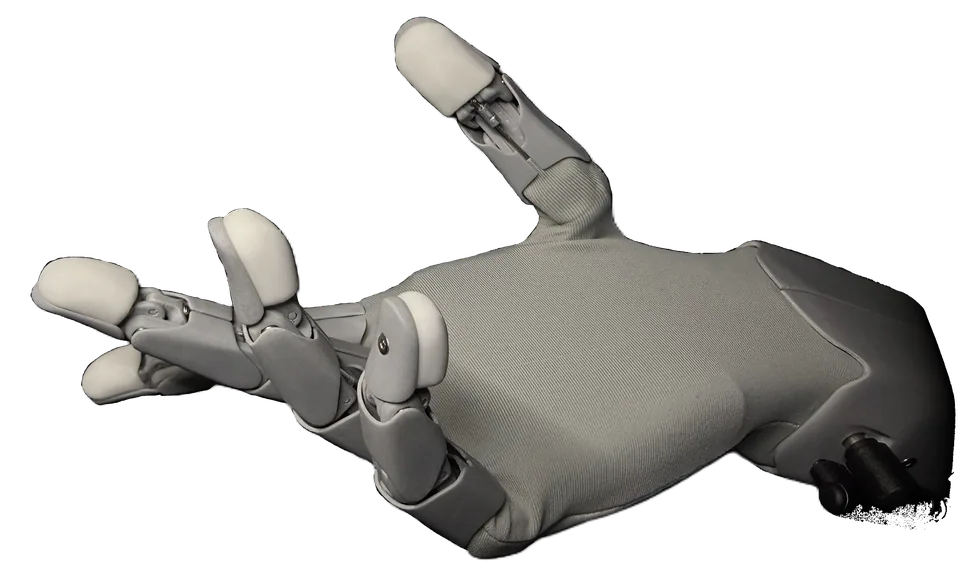
Photo: AGILINK, product page (agilink-ai.com)

OmniHand 3 Ultra-T

The OmniHand 3 Ultra-T is AGILINK's second flagship, built around tendons instead of in-joint motors: the actuators are mounted behind the hand and pull tendons, so the 1:1 human-scale hand itself weighs about 500 g while the complete assembly with wrist and actuator pack comes to roughly 1.7 kg according to the maker.

Price from

no public price
No confirmed distributor in Poland
  • 0.5kgWeight
  • 22DOFDegrees of freedom

Key facts

  • Specificationsweight 0.5 kg · degrees of freedom 22 DOF
  • Statuspilot
  • Availability in Polandnot confirmed

Summary

  • ManufacturerAGILINK
  • CategoryRobot hands
  • Statuspilot
  • Availability in PolandNo confirmed distributor in Poland

The OmniHand 3 Ultra-T is AGILINK's second flagship, built around tendons instead of in-joint motors: the actuators are mounted behind the hand and pull tendons, so the 1:1 human-scale hand itself weighs about 500 g while the complete assembly with wrist and actuator pack comes to roughly 1.7 kg according to the maker.

The hand offers 22 active degrees of freedom, and a three-axis wrist adds three more for 25 in total. The cycle time of 0.3 s matches the direct-drive sibling OmniHand 3 Ultra-M. Tactile sensing is distributed over the whole hand as three-dimensional sensors with 0.01 N resolution, and a camera sits in the palm.

Control modes cover force, position, velocity and hybrid regulation, with CAN-FD and EtherCAT as interfaces. AGILINK names research, industry and humanoids as target fields. The status is pilot: the maker presents the hand with a datasheet on its website, but the reseller Global Drone HQ noted in October 2026 that it had not been released for sale yet.

Load capacity, grip force and price are not published, so the hand is available on request only.

Specs

Sources: 2

Size and key figures
Size and key figures: OmniHand 3 Ultra-TWeight: 0.5 kg, category median 0.7 kg. Degrees of freedom: 22 , category median 16 .Figures against the category medianWeight0.5 kgcategory median: 0.7 kg (n=98)Degrees of freedom22category median: 16 (n=125)

Data from manufacturer datasheets and product pages; median over the models of this category in the database.

  • Weight0.5 kg
    −29% vs. the category median (0.7 kg, n=98)
  • Degrees of freedom22
    +38% vs. the category median (16, n=125)
  • category medianA higher value doesn't always mean a better robot; it depends on the application.

Dimensions and weight

Weight
0.5 kg

Motion and manipulation

Degrees of freedom
22

Electronics and AI

Drive
tendons, actuators mounted behind the hand
Sensors
distributed 3D tactile sensing over the whole hand (0.01 N), camera in the palm

Additional specs

Design type
tendon-driven five-finger hand
Interfaces
CAN-FD, EtherCAT
Fingers
5
Opposable thumb
yes
Tactile sensing
yes
Open source
no
Country of origin
CN

Datasheet (PDF)

Price and availability in Poland

no data

Dealers in Poland

No confirmed distributor in Poland

Applications

Typical applications

  • research, industry, humanoids

Target group

  • research labs, industrial integrators, humanoid makers

Comparison

Robot comparison tool

Similar models

  • HW1
    prototype

    Gesture Platforms

    HW1

    • 0.5 kgweight
    • 10 DOFdegrees of freedom
    • 3,300*price (PLN)
  • on sale

    Prensilia S.r.l.

    Mia Hand (Mk2)

    • 0.5 kgweight
    • 4 DOFdegrees of freedom
    • —price
  • on sale

    Open Droids

    DH116

    • 0.49 kgweight
    • 11 DOFdegrees of freedom
    • 12,000*price (PLN)
  • on sale

    AGILINK

    OmniHand 3 Ultra-M

    • 0.63 kgweight
    • 21 DOFdegrees of freedom
    • 93,000*price (PLN)
  • OmniHand (2025, O10)
    on sale

    AgiBot (Zhiyuan Robotics)

    OmniHand (2025, O10)

    • 0.51 kgweight
    • 16 DOFdegrees of freedom
    • 19,400*price (PLN)

History

  1. Model unveiled

Sources

  1. agilink-ai.com
  2. globaldronehq.com

Author, source and licence of the photo are given in the caption. Shop links may become affiliate links in future, details: How we make money · How we check