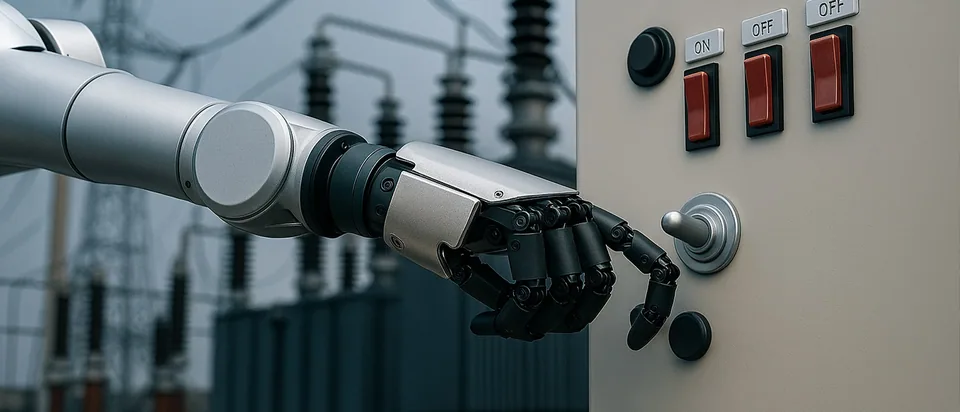
Photo: PL-Universe Robotics Technology Co., Ltd., product page (en.pl-universe.com)
Robot handson sale

PL-WitHand

PL-WitHand comes from PL-Universe, a company founded in January 2025 in Suzhou Industrial Park, and it mixes two drive principles: micro servo electric cylinders and micro servo motors housed in the hand move the fingers partly through tendons and partly through linkages.

Price from

no public price
No confirmed distributor in Poland
  • 0.8kgWeight
  • 20DOFDegrees of freedom
  • 10kgPayload

Key facts

  • Specificationsweight 0.8 kg · degrees of freedom 20 DOF · payload 10 kg
  • Statuson sale
  • Availability in Polandnot confirmed

Summary

PL-WitHand comes from PL-Universe, a company founded in January 2025 in Suzhou Industrial Park, and it mixes two drive principles: micro servo electric cylinders and micro servo motors housed in the hand move the fingers partly through tendons and partly through linkages. The maker describes the layout as 16+4 degrees of freedom, sixteen actuated and four passive, across five fingers with an integrated wrist.

The hand weighs 800 g, carries a 10 kg load and grips with 15 N at the thumb and 10 N at the other fingers; positioning repeats to ±0.20 mm. The sensor set is broad for a hand in this class: fingertip tactile sensors with 0.1 N resolution, image sensors, joint-angle sensors and six-axis force sensors. Integration runs through ROS 2. Dimensions and supply voltage are not published.

The hand is aimed at industry, research and services, and the price is on request. Among Chinese hands with a similar joint count it compares with the GMH18, which has denser tactile coverage, or the lighter Linker Hand O6, which offers far fewer degrees of freedom.

Specs

Sources: 2

Size and key figures
Size and key figures: PL-WitHandPayload: 10 kg, category median 15 kg. Weight: 0.8 kg, category median 0.7 kg.Figures against the category medianPayload10 kgcategory median: 15 kg (n=83)Weight0.8 kgcategory median: 0.7 kg (n=98)

Data from manufacturer datasheets and product pages; median over the models of this category in the database.

  • Weight0.8 kg
    +14% vs. the category median (0.7 kg, n=98)
  • Degrees of freedom20
    +25% vs. the category median (16, n=125)
  • Payload10 kg
    −33% vs. the category median (15 kg, n=83)
  • category medianA higher value doesn't always mean a better robot; it depends on the application.

Dimensions and weight

Weight
0.8 kg

Motion and manipulation

Degrees of freedom
20
Payload
10 kg

Electronics and AI

Drive
micro electric cylinders and micro servos in the hand, tendon-linkage hybrid
Sensors
fingertip tactile (0.1 N), image, angle and six-axis force sensors

Additional specs

Design type
five-finger hand
Interfaces
ROS 2
Fingers
5
Opposable thumb
yes
Actuators
16
Fingertip force (N)
15
Tactile sensing
yes
Open source
no
Country of origin
CN

Datasheet (PDF)

Price and availability in Poland

no data

Dealers in Poland

No confirmed distributor in Poland

Applications

Typical applications

  • industry, research, services

Target group

  • industrial integrators, labs

Comparison

Robot comparison tool

Similar models

  • CYBORG-HO2
    on sale

    Cyborg Robotics (Shenzhen Cyborg Robotics Co., Ltd. / 深圳赛博格机器人有限公司)
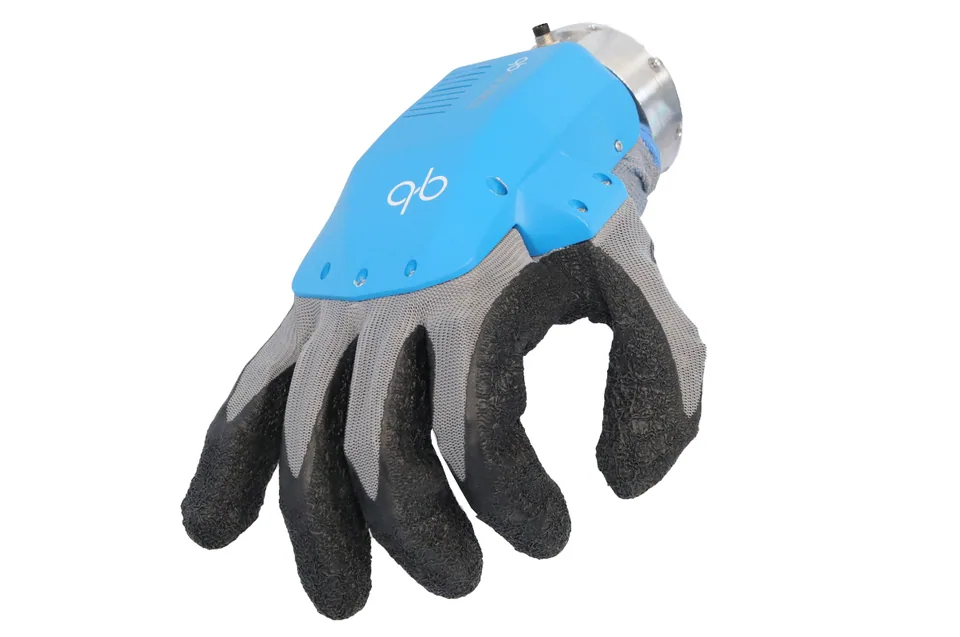
    CYBORG-HO2

    • 0.75 kgweight
    • 16 DOFdegrees of freedom
    • —price
  • on sale

    Tesollo Inc.

    DG-5F-S

    • 0.88 kgweight
    • 20 DOFdegrees of freedom
    • —price
  • on sale

    WUJI Tech (Wuji Technology)

    WUJI Hand 2

    • 0.8 kgweight
    • 20 DOFdegrees of freedom
    • 56,600*price (PLN)
  • research platform

    University of Illinois Urbana-Champaign (UIUC)
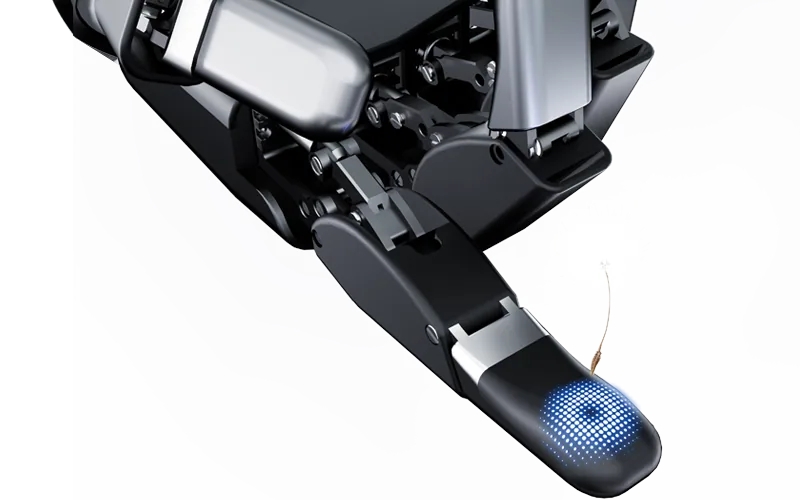
    CRAFT Hand

    • 0.8 kgweight
    • 20 DOFdegrees of freedom
    • —price
  • DH-5-6
    on sale

    DH-Robotics (Shenzhen DH-Robotics Technology Co., Ltd.)

    DH-5-6

    • 0.79 kgweight
    • 11 DOFdegrees of freedom
    • 21,300*price (PLN)

History

no data

Sources

  1. en.pl-universe.com
  2. en.pl-universe.com

Author, source and licence of the photo are given in the caption. Shop links may become affiliate links in future, details: How we make money · How we check