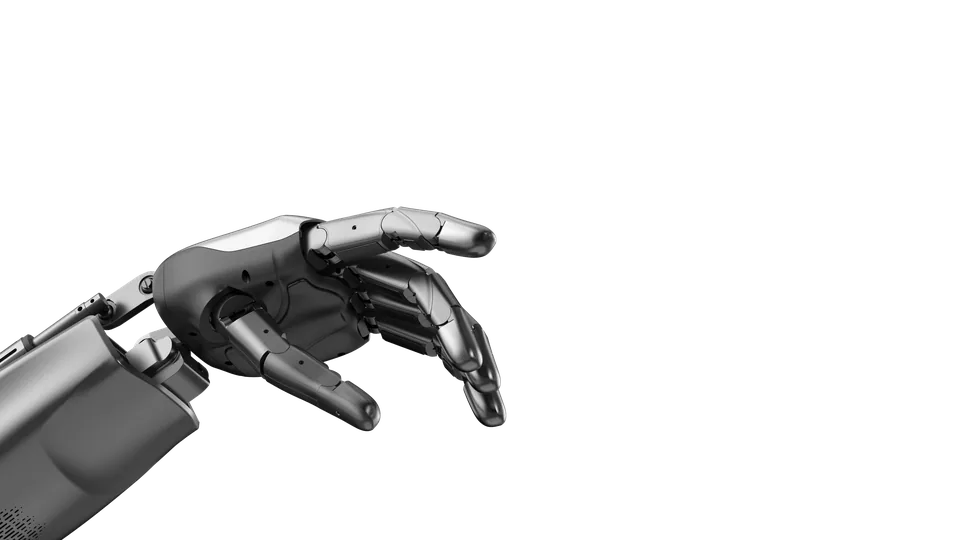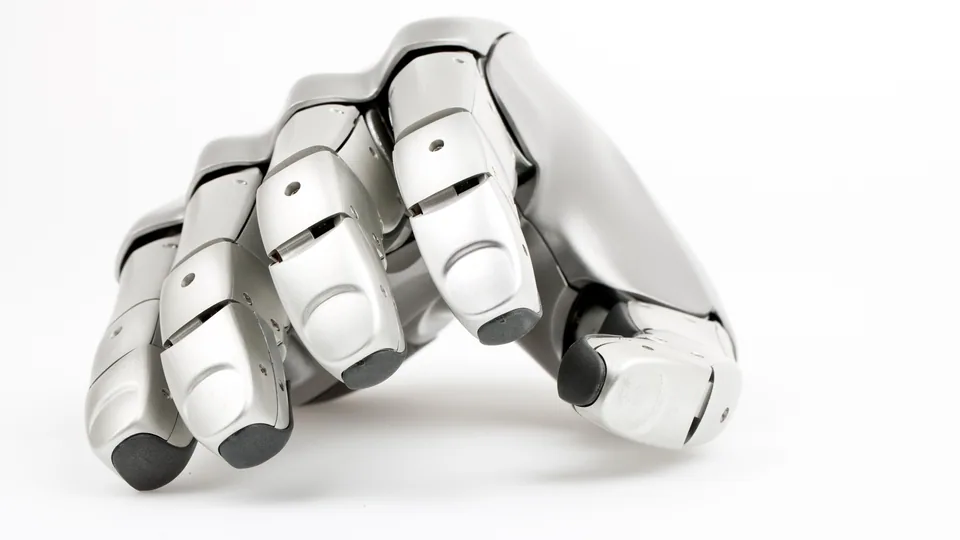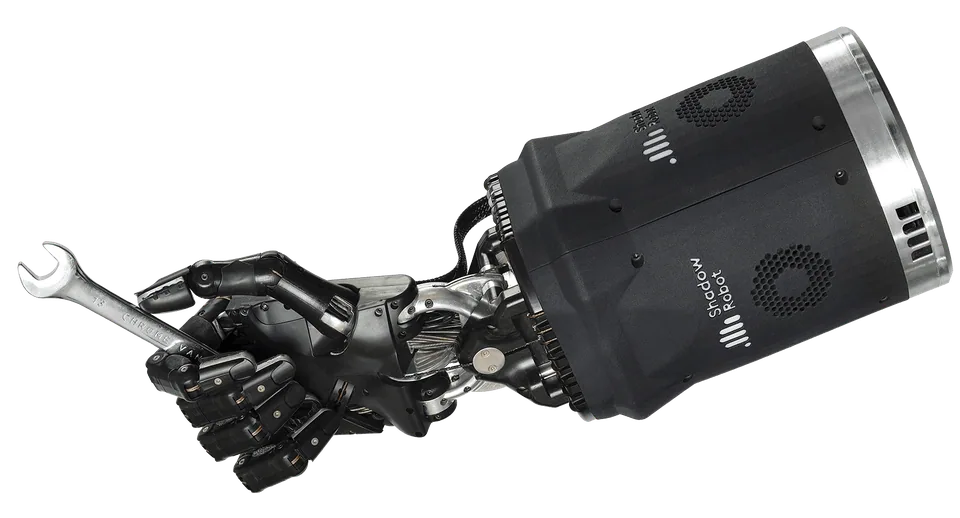
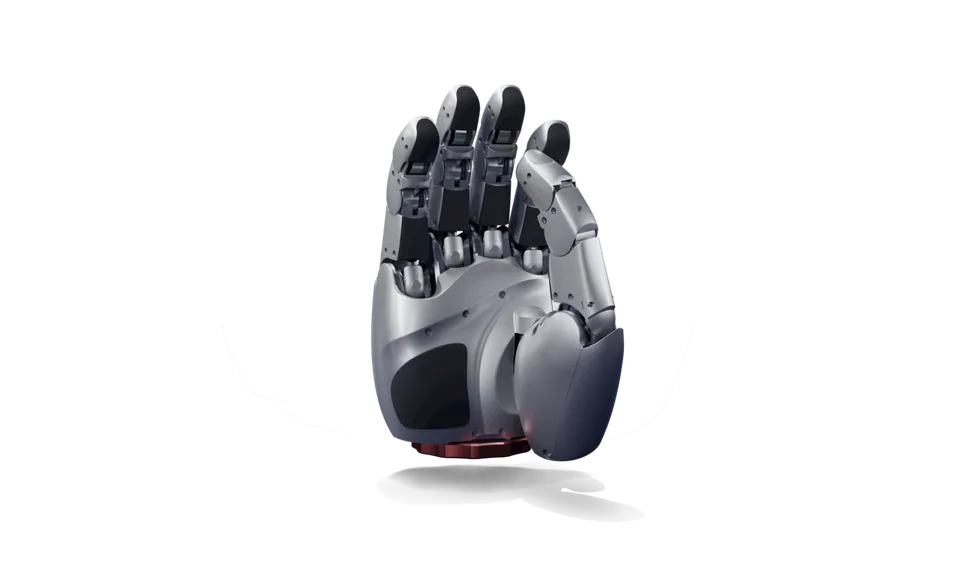
Photo: Handroid-Projekt, manufacturer's website (handroid.org)
Robot handsresearch platform

Handroid

Is it a hand or a humanoid? Handroid, an open academic project from UNC Chapel Hill and Stanford published on arXiv in July 2026, is both: a fully 3D-printed desktop robot that works as an anthropomorphic hand and can also stand on its fingers and walk as a small humanoid.

Price from

no public price
No confirmed distributor in Poland
  • 2.05kgWeight
  • 27DOFDegrees of freedom

Key facts

  • Specificationsweight 2.05 kg · degrees of freedom 27 DOF
  • Statusresearch platform
  • Availability in Polandnot confirmed

Summary

Is it a hand or a humanoid? Handroid, an open academic project from UNC Chapel Hill and Stanford published on arXiv in July 2026, is both: a fully 3D-printed desktop robot that works as an anthropomorphic hand and can also stand on its fingers and walk as a small humanoid.

It has 27 degrees of freedom in total, 20 of them in the hand, driven by compact modular actuators that report joint position, with an integrated control board handling power, sensing and status. The robot stands 0.33 m tall and weighs 2.05 kg. The authors demonstrate in-hand manipulation at a 30 Hz control rate and lifting a metal cup of about 270 g; they do not state payload or finger count.

Everything is released under the MIT licence with Onshape CAD and a bill of materials, although code and documentation are still being prepared. There is no price because it is a build-it-yourself design; only the parts cost money. A commercial hand in a similar budget class is HW1, and another university design is LEAP Hand.

Specs

Sources: 3

Size and key figures
Size and key figures: HandroidWeight: 2.05 kg, category median 0.7 kg. Degrees of freedom: 27 , category median 16 .Figures against the category medianWeight2.05 kgcategory median: 0.7 kg (n=98)Degrees of freedom27category median: 16 (n=125)

Data from manufacturer datasheets and product pages; median over the models of this category in the database.

  • Weight2.05 kg
    +193% vs. the category median (0.7 kg, n=98)
  • Degrees of freedom27
    +69% vs. the category median (16, n=125)
  • category medianA higher value doesn't always mean a better robot; it depends on the application.

Dimensions and weight

Weight
2.05 kg

Motion and manipulation

Degrees of freedom
27

Electronics and AI

Drive
compact modular actuators in the hand, 27 DOF (20 in the hand)
Sensors
joint position from the actuators, integrated control board

Additional specs

Design type
transformable research hand
Length (mm)
330
Tactile sensing
no
Open source
yes
Country of origin
US

Datasheet (PDF)

Price and availability in Poland

no data

Dealers in Poland

No confirmed distributor in Poland

Applications

Typical applications

  • research, open project under MIT licence

Target group

  • universities, labs

Comparison

Robot comparison tool

Similar models

  • DexMano D22-PRO
    prototype

    Suzhou Botyard Intelligence Technology Co., Ltd.
    DexMano D22-PRO

    • 1.8 kgweight
    • 22 DOFdegrees of freedom
    • —price
  • DG-5F (DG-5F-M)
    on sale

    Tesollo Inc.

    DG-5F (DG-5F-M)

    • 1.76 kgweight
    • 20 DOFdegrees of freedom
    • 67,800*price (PLN)
  • DLR-HIT Hand II
    research platform

    German Aerospace Center (DLR), Institute of Robotics and Mechatronics
    DLR-HIT Hand II

    • 1.5 kgweight
    • 15 DOFdegrees of freedom
    • —price
  • Agile Hand
    on sale

    Agile Robots SE

    Agile Hand

    • 1.5 kgweight
    • 16 DOFdegrees of freedom
    • —price
  • on sale

    Tesollo Inc.

    DG-4F

    • 1.49 kgweight
    • 18 DOFdegrees of freedom
    • —price

History

  1. Model unveiled

Sources

  1. handroid.org
  2. arxiv.org
  3. github.com

Author, source and licence of the photo are given in the caption. Shop links may become affiliate links in future, details: How we make money · How we check