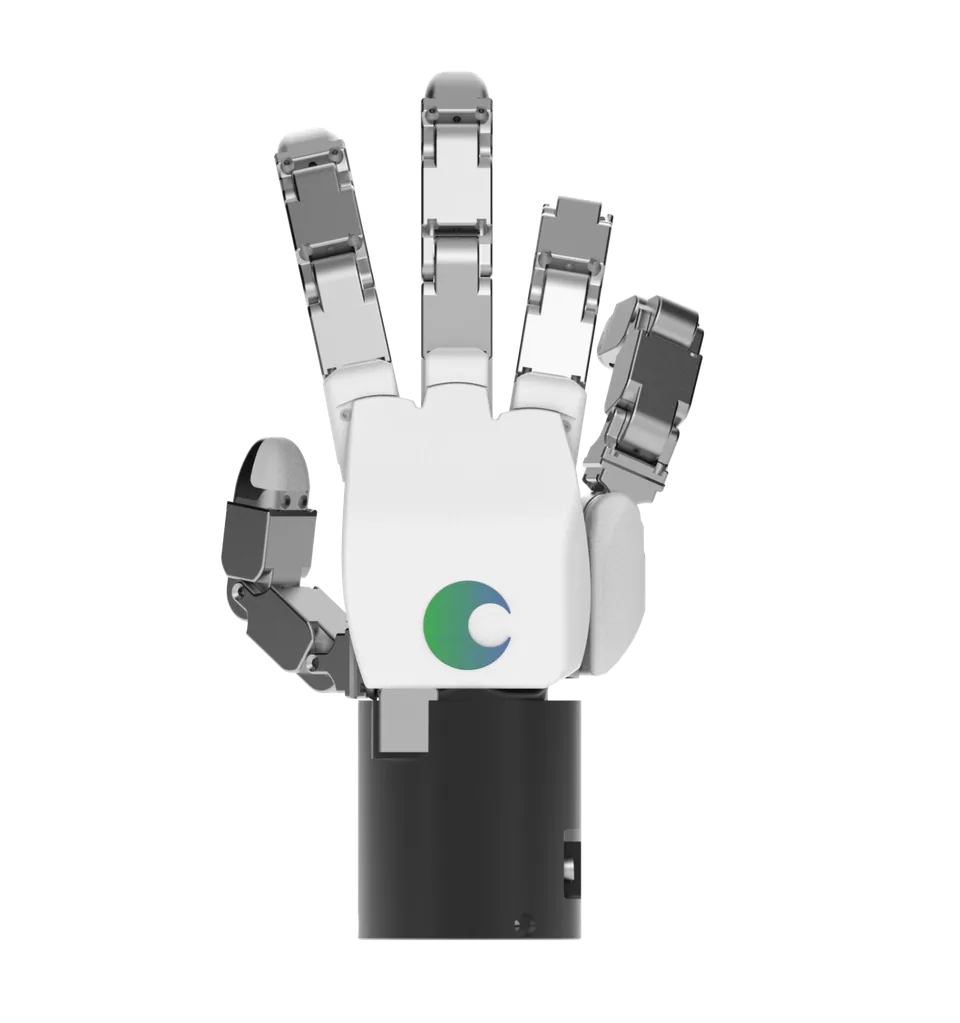
Photo: Suzhou Botyard Intelligence Technology Co., Ltd., manufacturer's website (botyard.ai)
Robot handsprototype

DexMano D22-PRO

Comparison tables attribute a hand called DexMano D22-PRO to Botyard Intelligence of Suzhou, yet the maker's own website documents only the Gaoshan S1 and never confirms the D22-PRO name; the matching figures (22 degrees of freedom, 1.8 kg, tactile sensing) point to the same product, so the data below come from the Gaoshan S1 sheet, version 0.1 of September 2026.

Price from

no public price
No confirmed distributor in Poland
  • 1.8kgWeight
  • 22DOFDegrees of freedom
  • 25kgPayload

Key facts

  • Specificationsweight 1.8 kg · degrees of freedom 22 DOF · payload 25 kg
  • Statusprototype
  • Availability in Polandnot confirmed

Summary

Comparison tables attribute a hand called DexMano D22-PRO to Botyard Intelligence of Suzhou, yet the maker's own website documents only the Gaoshan S1 and never confirms the D22-PRO name; the matching figures (22 degrees of freedom, 1.8 kg, tactile sensing) point to the same product, so the data below come from the Gaoshan S1 sheet, version 0.1 of September 2026.

The hand has 22 joints and 18 active degrees of freedom, four in the thumb and three per finger, with a tendon drive that combines tendons, linkages and direct drive and houses the actuator unit in a forearm module; including that module it measures 109.9 x 92.33 x 439.45 mm and weighs 1.8 kg. Fingertip force is 30 N, grip force 100 N, lifting force 25 kg, and the smallest graspable object 9 mm.

Fingers open and close at 3 Hz, a joint reaches 360 degrees per second, the control loop runs above 1 kHz and reaction time stays under 0.3 s. Three-dimensional fingertip tactile sensors carry 116 measuring points each with a 0.1 N threshold and 1 mm spatial resolution, joined by a six-axis IMU, joint angles and tendon monitoring of voltage, current, temperature and tension.

Interfaces are EtherCAT at 500 Hz, RS-485 at 200 Hz and CAN FD at 100 Hz, with ROS 2 via ros2_control, a C++ SDK and URDF, MJCF and USD models; control is by position or force, and a Juexian desktop client handles operation. Power is 24 V DC at 7.5 A, cooling is by air, the operating range 0 to 45 degrees Celsius, and the variants are S1-L-FT, S1-R-FT and S1-LR-FT.

The status is prototype for humanoids and research; the order form lists no price, so it is available on request. A comparable forearm-actuated design is the OmniHand 3 Ultra-T.

Specs

Sources: 3

Size and key figures
Size and key figures: DexMano D22-PROPayload: 25 kg, category median 15 kg. Weight: 1.8 kg, category median 0.7 kg.Figures against the category medianPayload25 kgcategory median: 15 kg (n=83)Weight1.8 kgcategory median: 0.7 kg (n=98)

Data from manufacturer datasheets and product pages; median over the models of this category in the database.

  • Weight1.8 kg
    +157% vs. the category median (0.7 kg, n=98)
  • Degrees of freedom22
    +38% vs. the category median (16, n=125)
  • Payload25 kg
    +67% vs. the category median (15 kg, n=83)
  • category medianA higher value doesn't always mean a better robot; it depends on the application.

Dimensions and weight

Weight
1.8 kg

Motion and manipulation

Degrees of freedom
22
Payload
25 kg

Electronics and AI

Drive
tendons, linkages and direct drive, actuator unit in the forearm module
Sensors
3D fingertip tactile sensors (116 points, 0.1 N threshold), six-axis IMU, joint angles, tendon monitoring

Additional specs

Design type
tendon-driven five-finger hand, prototype
Interfaces
EtherCAT 500 Hz, RS-485 200 Hz, CAN FD 100 Hz, ROS 2, C++ SDK, URDF/MJCF/USD
Fingers
5
Opposable thumb
yes
Grip force (N)
100
Fingertip force (N)
30
Length (mm)
439
Tactile sensing
yes
Supply voltage (V)
24
Open source
no
Country of origin
CN

Datasheet (PDF)

Price and availability in Poland

no data

Dealers in Poland

No confirmed distributor in Poland

Applications

Typical applications

  • humanoids, research

Target group

  • humanoid makers, manipulation research labs

Comparison

Robot comparison tool

Similar models

  • Handroid
    research platform

    Handroid-Projekt (UNC Chapel Hill / Stanford University)
    Handroid

    • 2.05 kgweight
    • 27 DOFdegrees of freedom
    • —price
  • Agile Hand
    on sale

    Agile Robots SE

    Agile Hand

    • 1.5 kgweight
    • 16 DOFdegrees of freedom
    • —price
  • on sale

    Sharpa (Sharpa Pte Ltd)

    SharpaWave (Wave W01)

    • 1.3 kgweight
    • 22 DOFdegrees of freedom
    • —price
  • prototype

    Festo SE & Co. KG

    BionicSoftHand 2.0

    • 1.29 kgweight
    • 11 DOFdegrees of freedom
    • —price
  • DG-5F (DG-5F-M)
    on sale

    Tesollo Inc.

    DG-5F (DG-5F-M)

    • 1.76 kgweight
    • 20 DOFdegrees of freedom
    • 67,800*price (PLN)
  • on sale

    Tesollo Inc.

    DG-4F

    • 1.49 kgweight
    • 18 DOFdegrees of freedom
    • —price

History

no data

Sources

  1. botyard.ai
  2. botyard.ai
  3. botyard.ai

Author, source and licence of the photo are given in the caption. Shop links may become affiliate links in future, details: How we make money · How we check