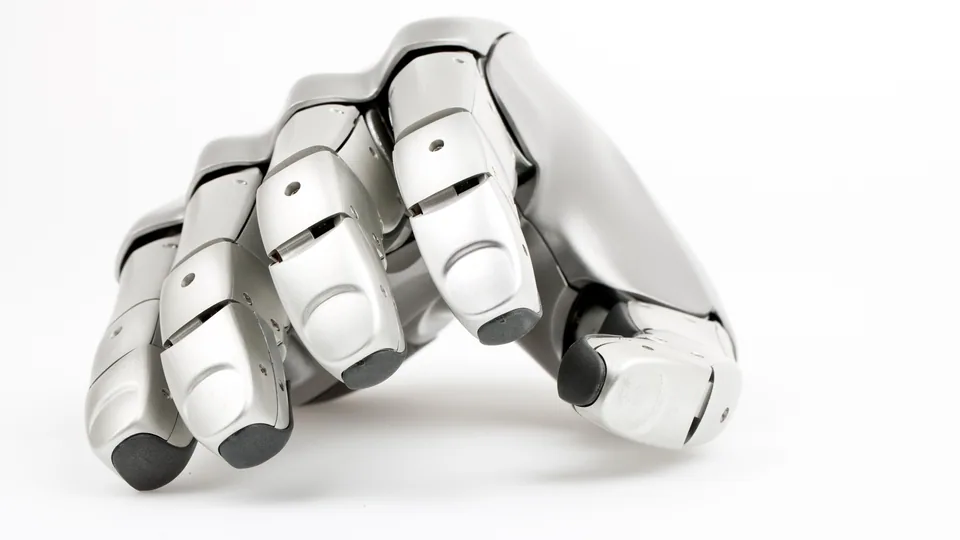
research platform
German Aerospace Center (DLR), Institute of Robotics and Mechatronics
DLR-HIT Hand II
- 1.5 kgweight
- 15 DOFdegrees of freedom
- —price
Agile Robots builds the Agile Hand in Munich as an anthropomorphic five-finger hand assembled from five identical finger modules.
Agile Robots builds the Agile Hand in Munich as an anthropomorphic five-finger hand assembled from five identical finger modules. Each module carries four joints, one of them coupled, so the complete hand has 21 joints and 16 degrees of freedom; the maker's website also mentions a 15-DOF count, while the current product flyer states 16.
Actuators sit inside every finger module, and each active joint reports torque and position, which allows active compliant control in torque or position mode. A tactile sensor is available as an option.
The hand weighs 1.5 kg, delivers 10 N of active fingertip force and moves its joints at up to 360 degrees per second; the distal joint travels 0 to 90 degrees, the proximal joint from minus 4 to 90, the metacarpal joint from minus 4 to 80, with 40 degrees of finger spread. The skeleton is aluminium with injection-moulded shells.
Control runs over EtherCAT at 1 kHz, the mechanical interface is an ISO 9409-1-50-4-M6 flange, and developers can use a C++ and Python API or ROS. The maker names research, industry, humanoids and spaceflight as fields of use and states that a space-qualified version has already flown. No load rating in kilograms is published.
Compared with the Shadow Dexterous Hand, the Agile Hand uses fewer joints but puts torque sensing into every one of them. Price on request.
Data from manufacturer datasheets and product pages; median over the models of this category in the database.
no data
No confirmed distributor in Poland
German Aerospace Center (DLR), Institute of Robotics and Mechatronics
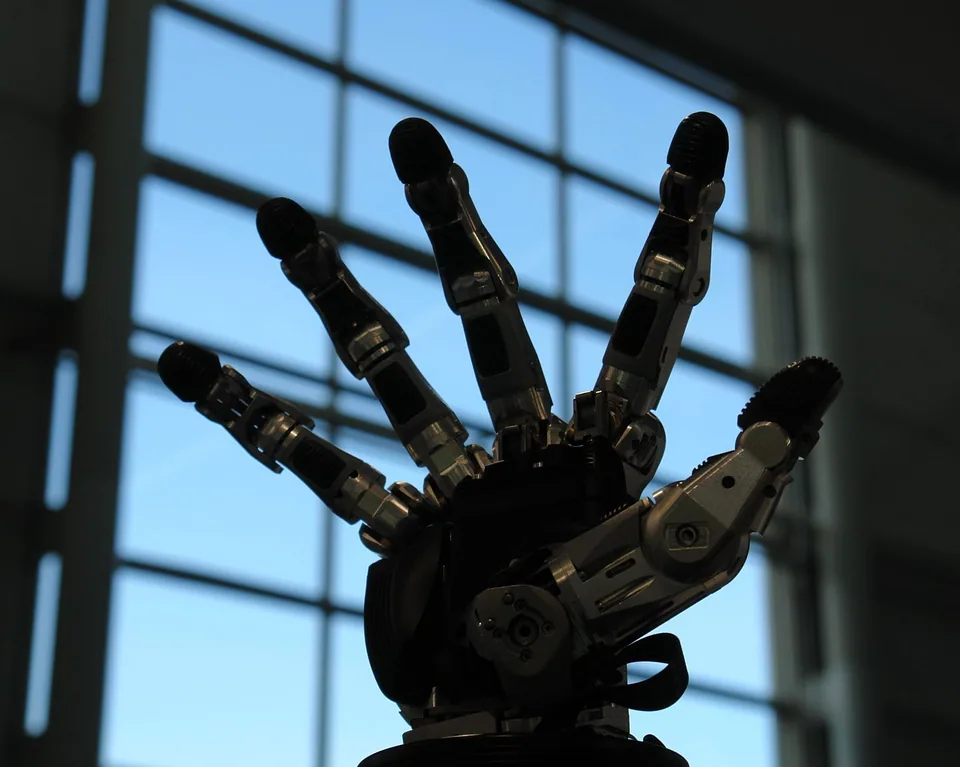
Agile Robots SE unveils 'Agile ONE', an industrial humanoid, at Hannover Messe Agile Robots SE
Author, source and licence of the photo are given in the caption. Shop links may become affiliate links in future, details: How we make money · How we check