on sale
Data from manufacturer datasheets and product pages; median over the models of this category in the database.
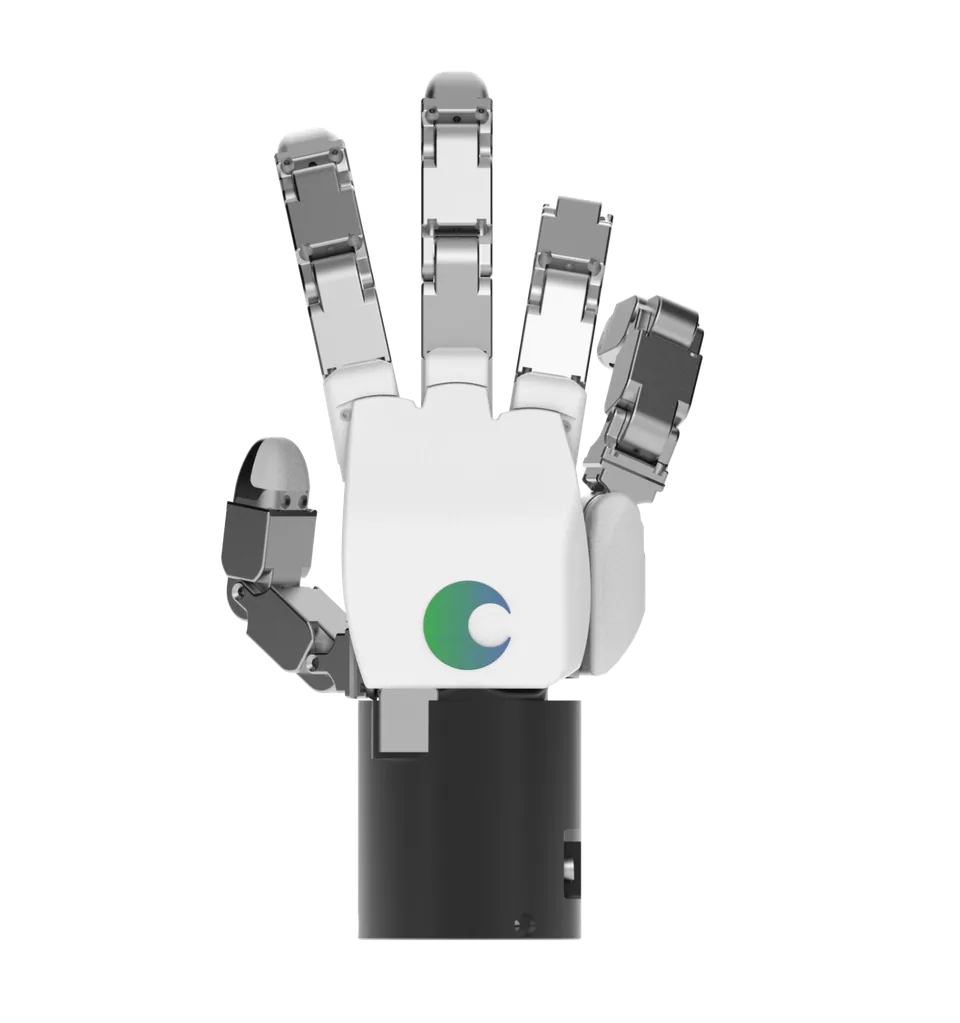
The DG-4F sits between an industrial gripper and a dexterous hand. Tesollo builds it with four fingers and 18 joints, every one of them driven by its own servo and fitted with an absolute encoder, so no joint is coupled to another.
The DG-4F sits between an industrial gripper and a dexterous hand. Tesollo builds it with four fingers and 18 joints, every one of them driven by its own servo and fitted with an absolute encoder, so no joint is coupled to another.
The control loop runs at 333 Hz, the hand weighs 1,494 g and runs on 24 V with a maximum current of 10 A. Payload depends on the grip: a pinch holds 3 kg nominally and 5 kg at most, while an envelope grip is rated at 10 kg and reaches 20 kg depending on friction.
Current and position feedback are standard; fingertips with a six-axis force-torque sensor, a three-axis force sensor, a tactile pad or a suction cup are optional. Integration goes through Modbus RTU and TCP or Ethernet TCP/IP, with an SDK, ROS 2 support via ros2_control and Gazebo models. Pinch, power and precision grasps are preconfigured. The hand is sold worldwide; the price is available on request.
For tasks that need a fifth finger, Tesollo offers the heavier DG-5F, while Dex3-1 shows what a lighter three-finger design looks like.
no data
No confirmed distributor in Poland
German Aerospace Center (DLR), Institute of Robotics and Mechatronics
no data
Shop links may become affiliate links in future, details: How we make money · How we check