on sale
no official photo
Data from manufacturer datasheets and product pages; median over the models of this category in the database.
Robot handson sale
Linker Hand L30 Pro
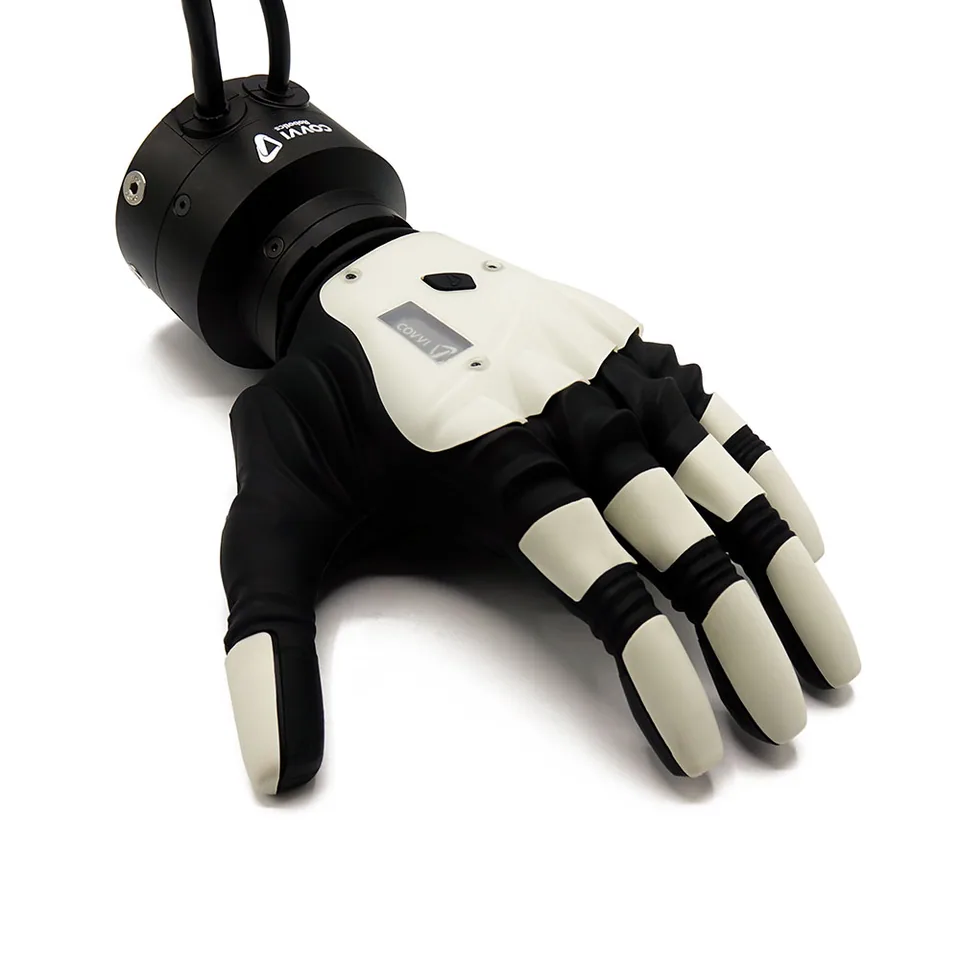
LinkerBot's current flagship, the Linker Hand L30 Pro, replaced the original Linker Hand L30 on the maker's site. The architecture is unchanged in outline: 21 joints across five fingers, 17 driven by forearm motors through tendons and four passive.
- 1.2kgWeight
- 21DOFDegrees of freedom
- 15kgPayload
Key facts
- Specificationsweight 1.2 kg · degrees of freedom 21 DOF · payload 15 kg
- Statuson sale
- Availability in Polandnot confirmed
Summary
- ManufacturerLinkerBot (灵心巧手)
- CategoryRobot hands
- Statuson sale
- Availability in PolandNo confirmed distributor in Poland
LinkerBot's current flagship, the Linker Hand L30 Pro, replaced the original Linker Hand L30 on the maker's site. The architecture is unchanged in outline: 21 joints across five fingers, 17 driven by forearm motors through tendons and four passive. What changed is speed and sensing.
The hand opens or closes in 0.2 s, finger flexion reaches 6.34 rad/s, and each fingertip carries a tactile array that the maker says can recognise objects; high-resolution encoders report joint positions. The maker gives the weight as roughly 1.2 kg, the rated load as 15 kg and the grip as 39 N, with 9 N per finger and 6.5 N at the thumb.
Control is by position with ±0.2 mm repeatability over a single CAN FD link running at 900 Hz. Power is 24 V, drawing 0.16 A at rest and up to 2.7 A under load. Intended users are humanoid developers and research groups; no list price is published, so the hand is quoted on request.
Specs
-
Weight1.2 kg+71% vs. the category median (0.7 kg, n=98)
-
Degrees of freedom21+31% vs. the category median (16, n=125)
-
Payload15 kgin line with the category median (15 kg, n=83)
- category medianA higher value doesn't always mean a better robot; it depends on the application.
Dimensions and weight
- Weight
- 1.2 kg
Motion and manipulation
- Degrees of freedom
- 21
- Payload
- 15 kg
Electronics and AI
- Drive
- tendons, 17 forearm motors
- Sensors
- fingertip tactile arrays with object recognition, high-resolution encoders
Additional specs
- Design type
- five-finger hand
- Interfaces
- CAN FD (900 Hz)
- Fingers
- 5
- Opposable thumb
- yes
- Actuators
- 17
- Grip force (N)
- 39
- Fingertip force (N)
- 9
- Tactile sensing
- yes
- Supply voltage (V)
- 24
- Open source
- no
- Country of origin
- CN
Price and availability in Poland
no data
Dealers in Poland
No confirmed distributor in Poland
Applications
Typical applications
Target group
Comparison
Robot comparison toolSimilar models
- on sale
- prototype
PsiBot (Shanghai PsiBot Technology Co., Ltd. / 上海灵初智能科技有限公司)
Psi H1
- 1.1 kgweight
- 21 DOFdegrees of freedom
- —price
- on sale
- on sale
 on sale
History
no data
Sources
Shop links may become affiliate links in future, details: How we make money · How we check