pilot
Robot handsin service
mimic hand M1
Announced on 16 July 2026, the mimic hand M1 is the hardware half of a full-stack approach: the Zurich company mimic Robotics supplies it only together with its own physical-AI models rather than as a stand-alone product.
- 15DOFDegrees of freedom
- 25kgPayload
Key facts
- Specificationsdegrees of freedom 15 DOF · payload 25 kg
- Statusin service
- Availability in Polandnot confirmed
Summary
- Manufacturermimic Robotics AG
- CategoryRobot hands
- Statusin service
- Availability in PolandNo confirmed distributor in Poland
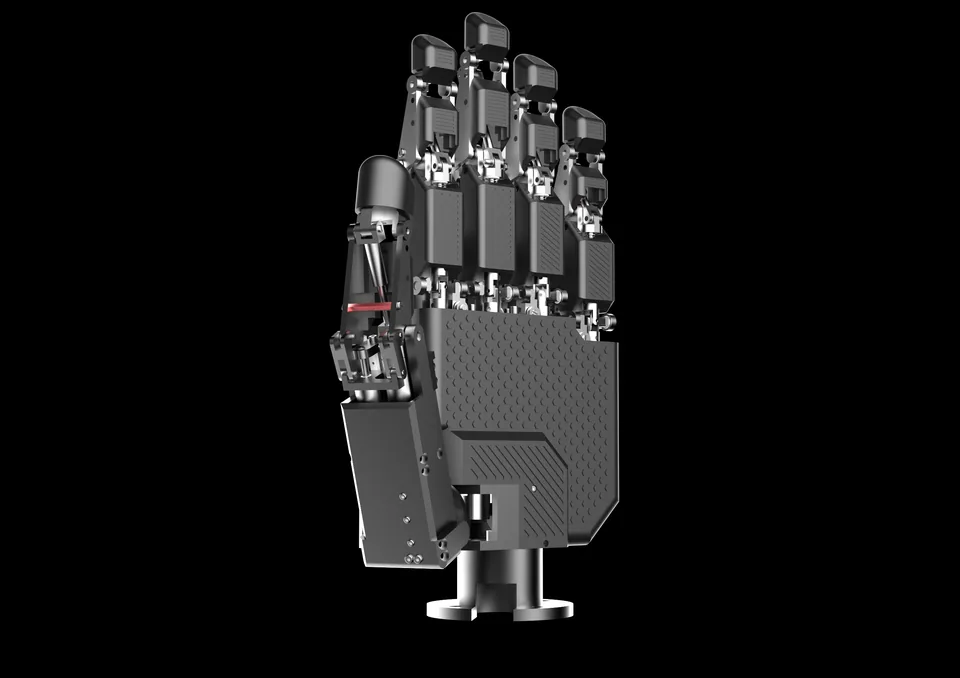
Announced on 16 July 2026, the mimic hand M1 is the hardware half of a full-stack approach: the Zurich company mimic Robotics supplies it only together with its own physical-AI models rather than as a stand-alone product. Five fingers carry 21 joints, 15 of them actuated and six coupled.
The motors live in the forearm and pull tendons bidirectionally over roller guides, giving a power-grasp payload above 25 kg and 25 N at the fingertip; the knuckle joints flex 135 degrees, abduct 55 degrees and hyperextend 45 degrees.
Fingertip sensors register normal force, shear force and multi-point contact, motor current adds force estimates finer than 0.1 N, and synchronised global-shutter cameras complete the picture. Closed-loop control places a fingertip to within ±0.18 mm, back-drive torque stays below 0.05 Nm, and active air cooling supports continuous operation. The maker does not state the weight or the communication interfaces.
Customers are industrial users and teleoperation set-ups; because the hand is bundled with the software, pricing is on request. For a Zurich tendon hand that is sold on its own, see OrcaHand.
Specs
Data from manufacturer datasheets and product pages; median over the models of this category in the database.
-
Degrees of freedom15−6% vs. the category median (16, n=125)
-
Payload25 kg+67% vs. the category median (15 kg, n=83)
- category medianA higher value doesn't always mean a better robot; it depends on the application.
Motion and manipulation
- Degrees of freedom
- 15
- Payload
- 25 kg
Electronics and AI
- Drive
- tendons, forearm motors, roller guides
- Sensors
- fingertip normal and shear force sensors, motor current, global-shutter cameras
Additional specs
- Design type
- five-finger hand
- Fingers
- 5
- Opposable thumb
- yes
- Fingertip force (N)
- 25
- Tactile sensing
- yes
- Open source
- no
- Country of origin
- CH
Price and availability in Poland
no data
Dealers in Poland
No confirmed distributor in Poland
Applications
Typical applications
Target group
Comparison
Robot comparison toolSimilar models
- prototype
 on sale
 pilot
- on sale
 research platform
German Aerospace Center (DLR), Institute of Robotics and Mechatronics
DLR-HIT Hand II
- 1.5 kgweight
- 15 DOFdegrees of freedom
- —price
History
Model unveiled
Sources
Author, source and licence of the photo are given in the caption. Shop links may become affiliate links in future, details: How we make money · How we check